01
Runs with the network off
Detection, tracking and fusion run on the node. No data centre, no cloud, no link required.
 HARDPOINT/AI
Contact
Software
The operating layer for systems that must decide without the network.
EdgeOS runs on the node, turns raw sensor streams into tracks and events, and keeps working when the link is jammed or gone. It sends only what matters, when it is allowed to.
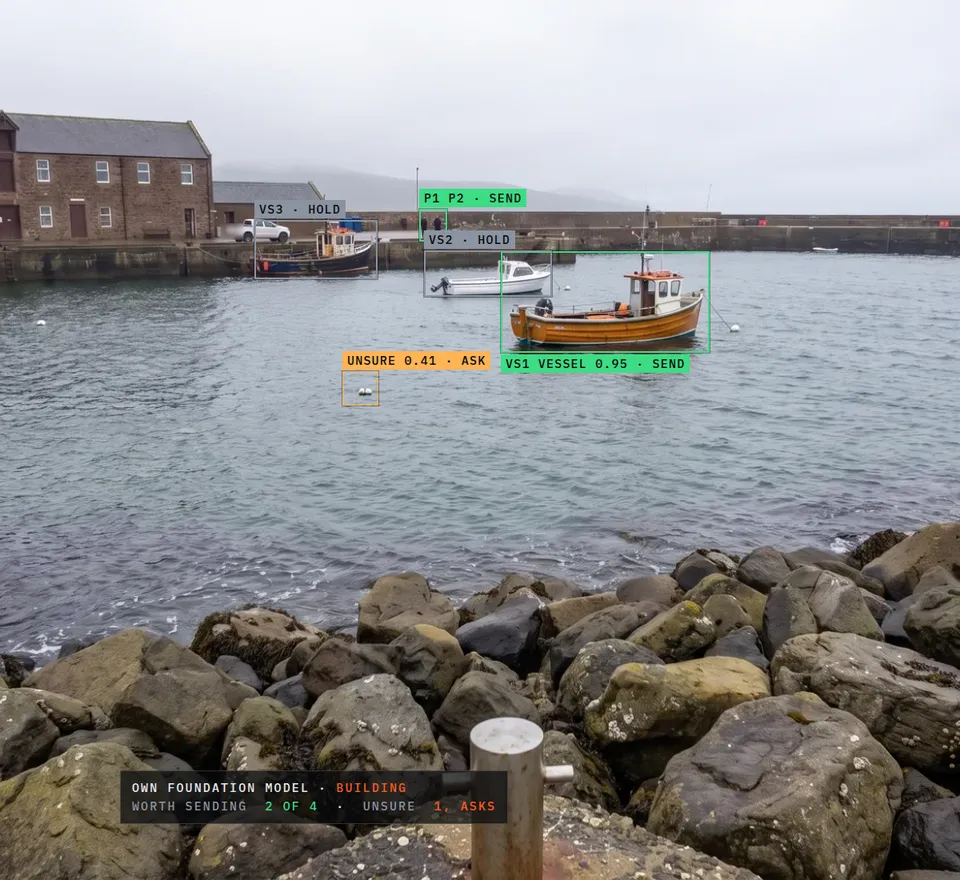
Sensors multiply every year, and the link back is the first thing to fail. Streaming raw video to a data centre assumes a network the field rarely has. EdgeOS does the work where the data is, and sends only what matters.
How it works
What the models find
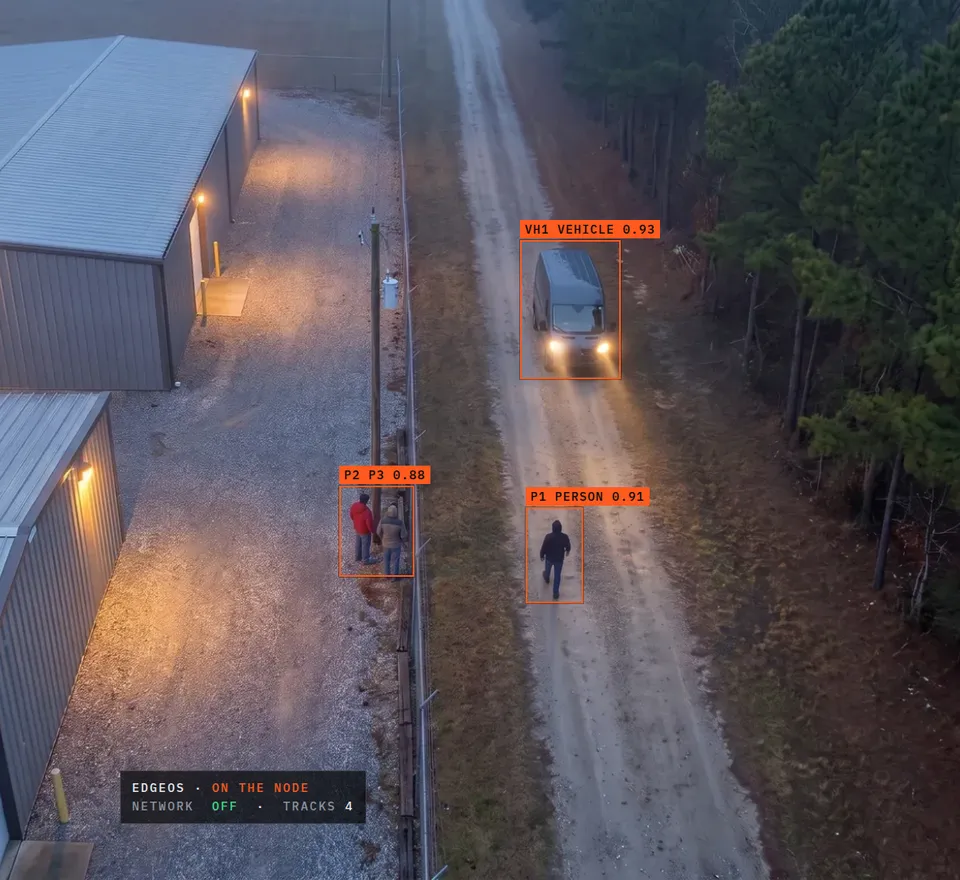
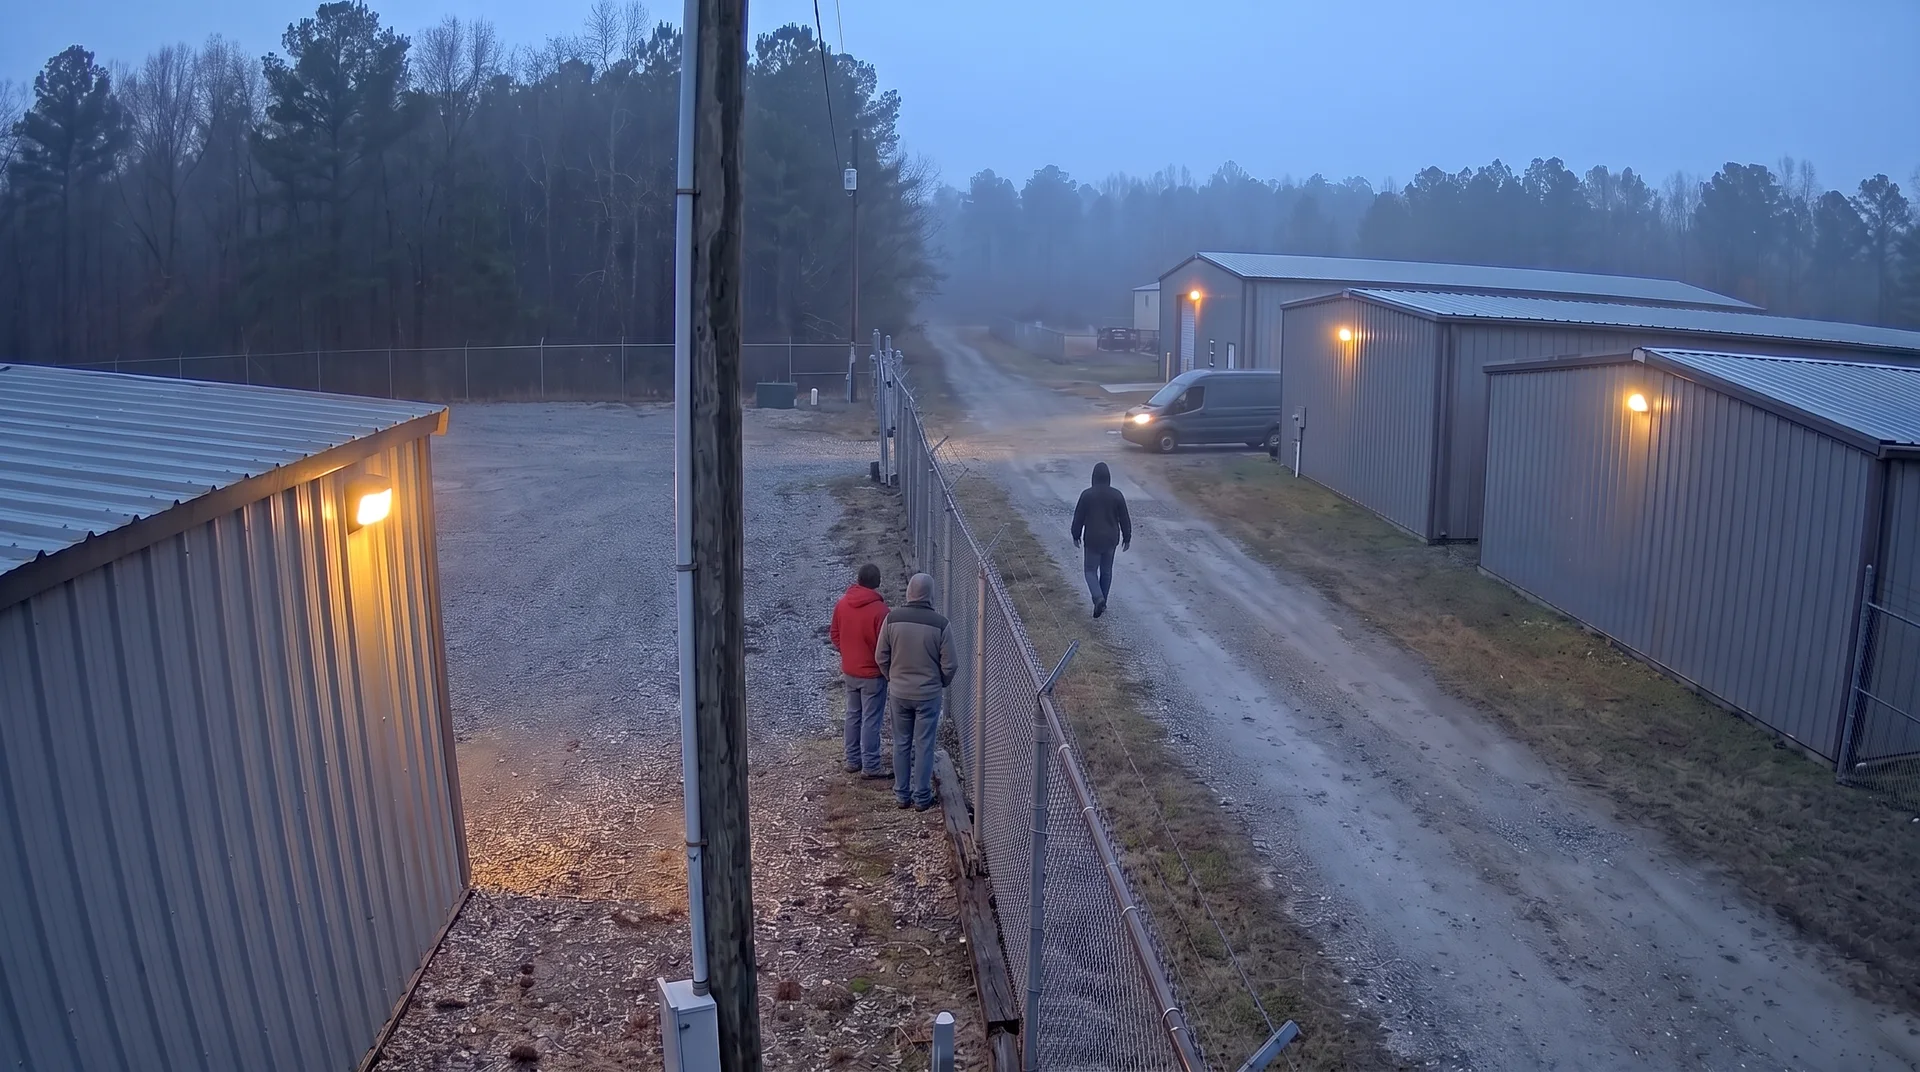
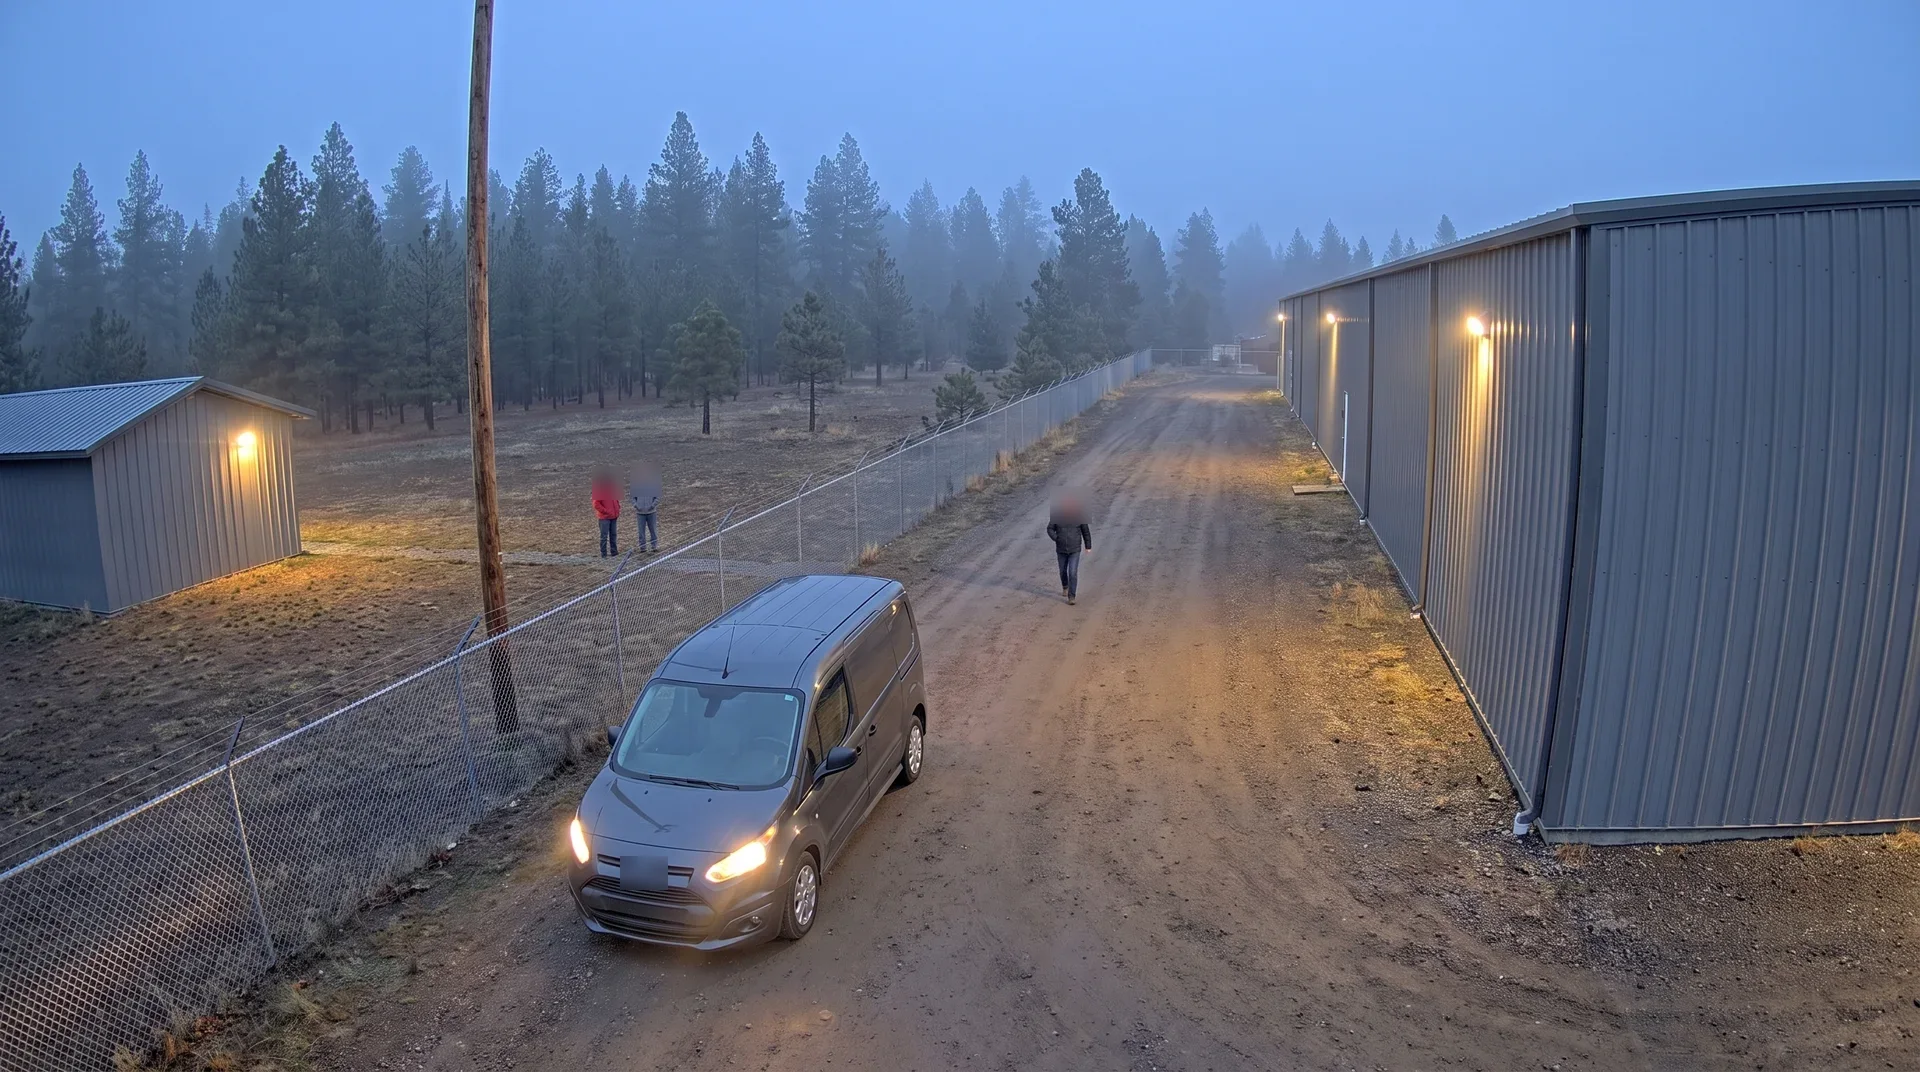
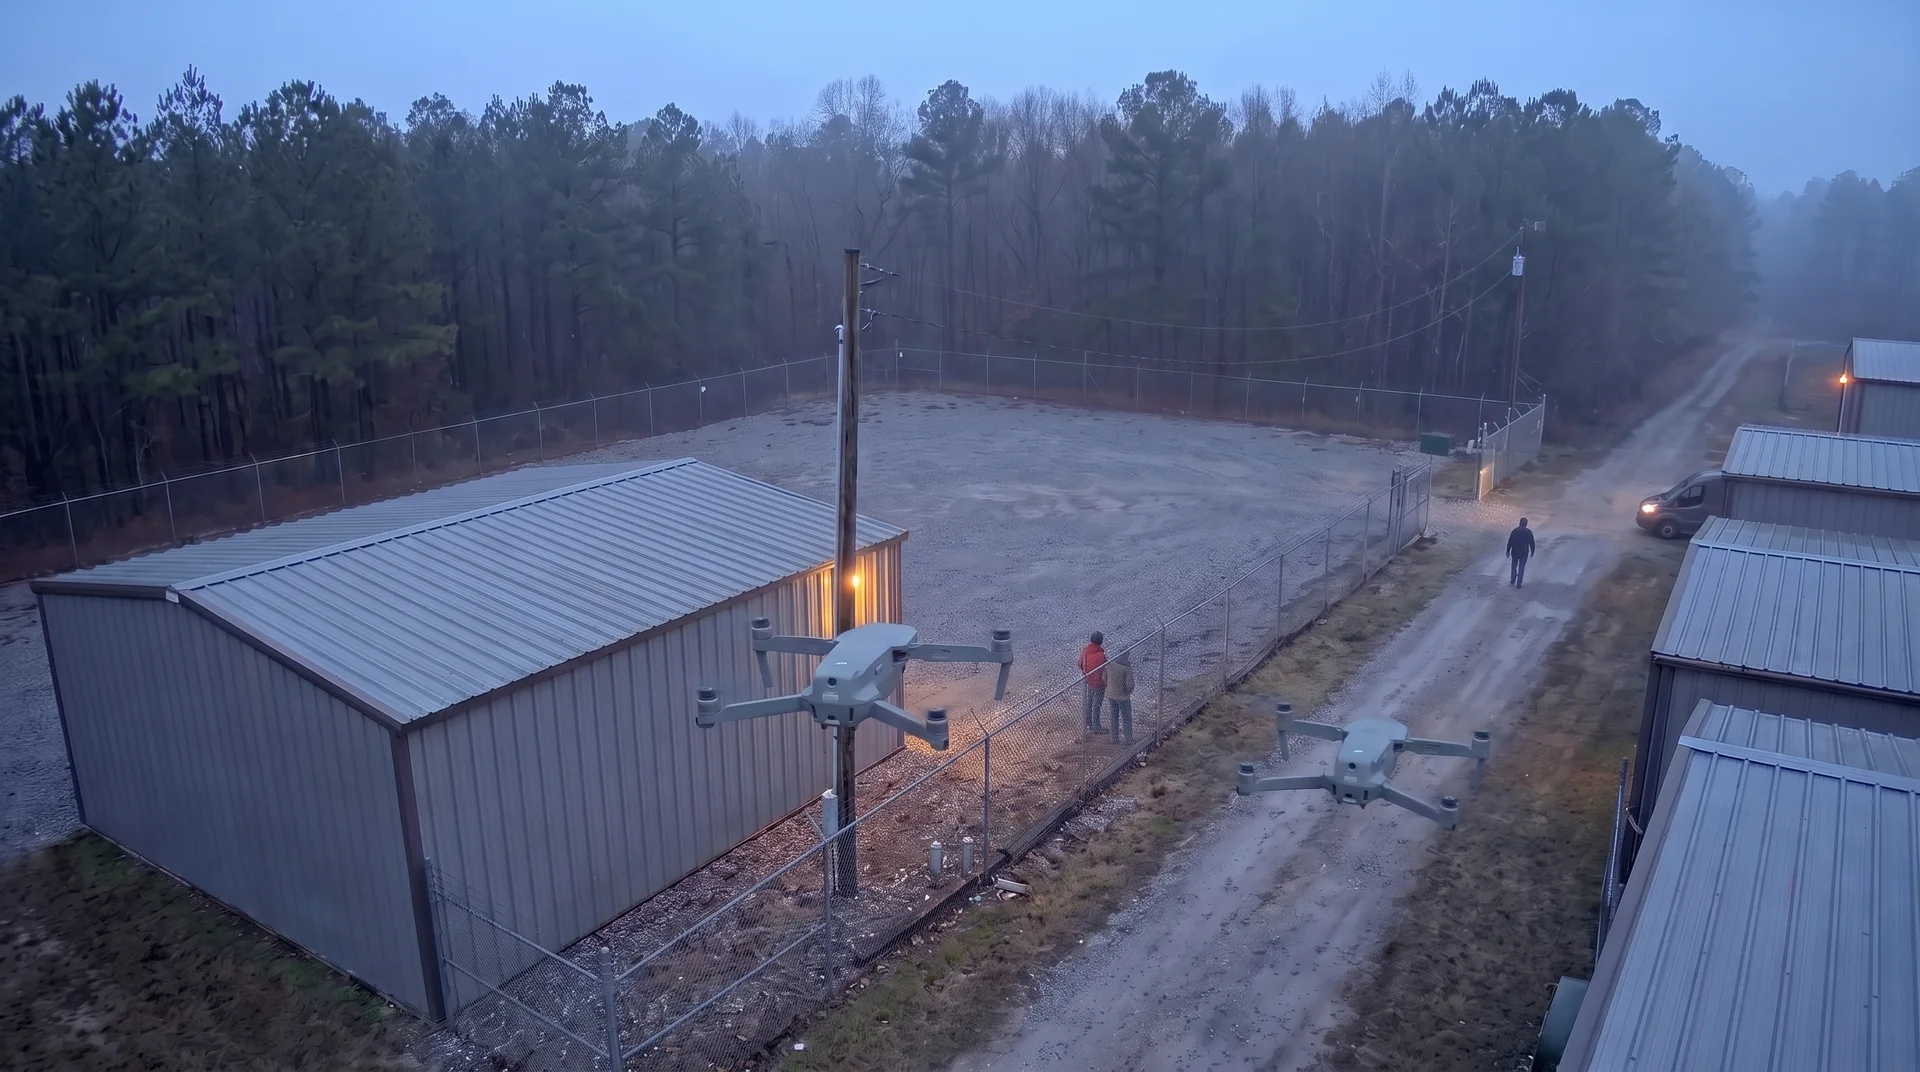
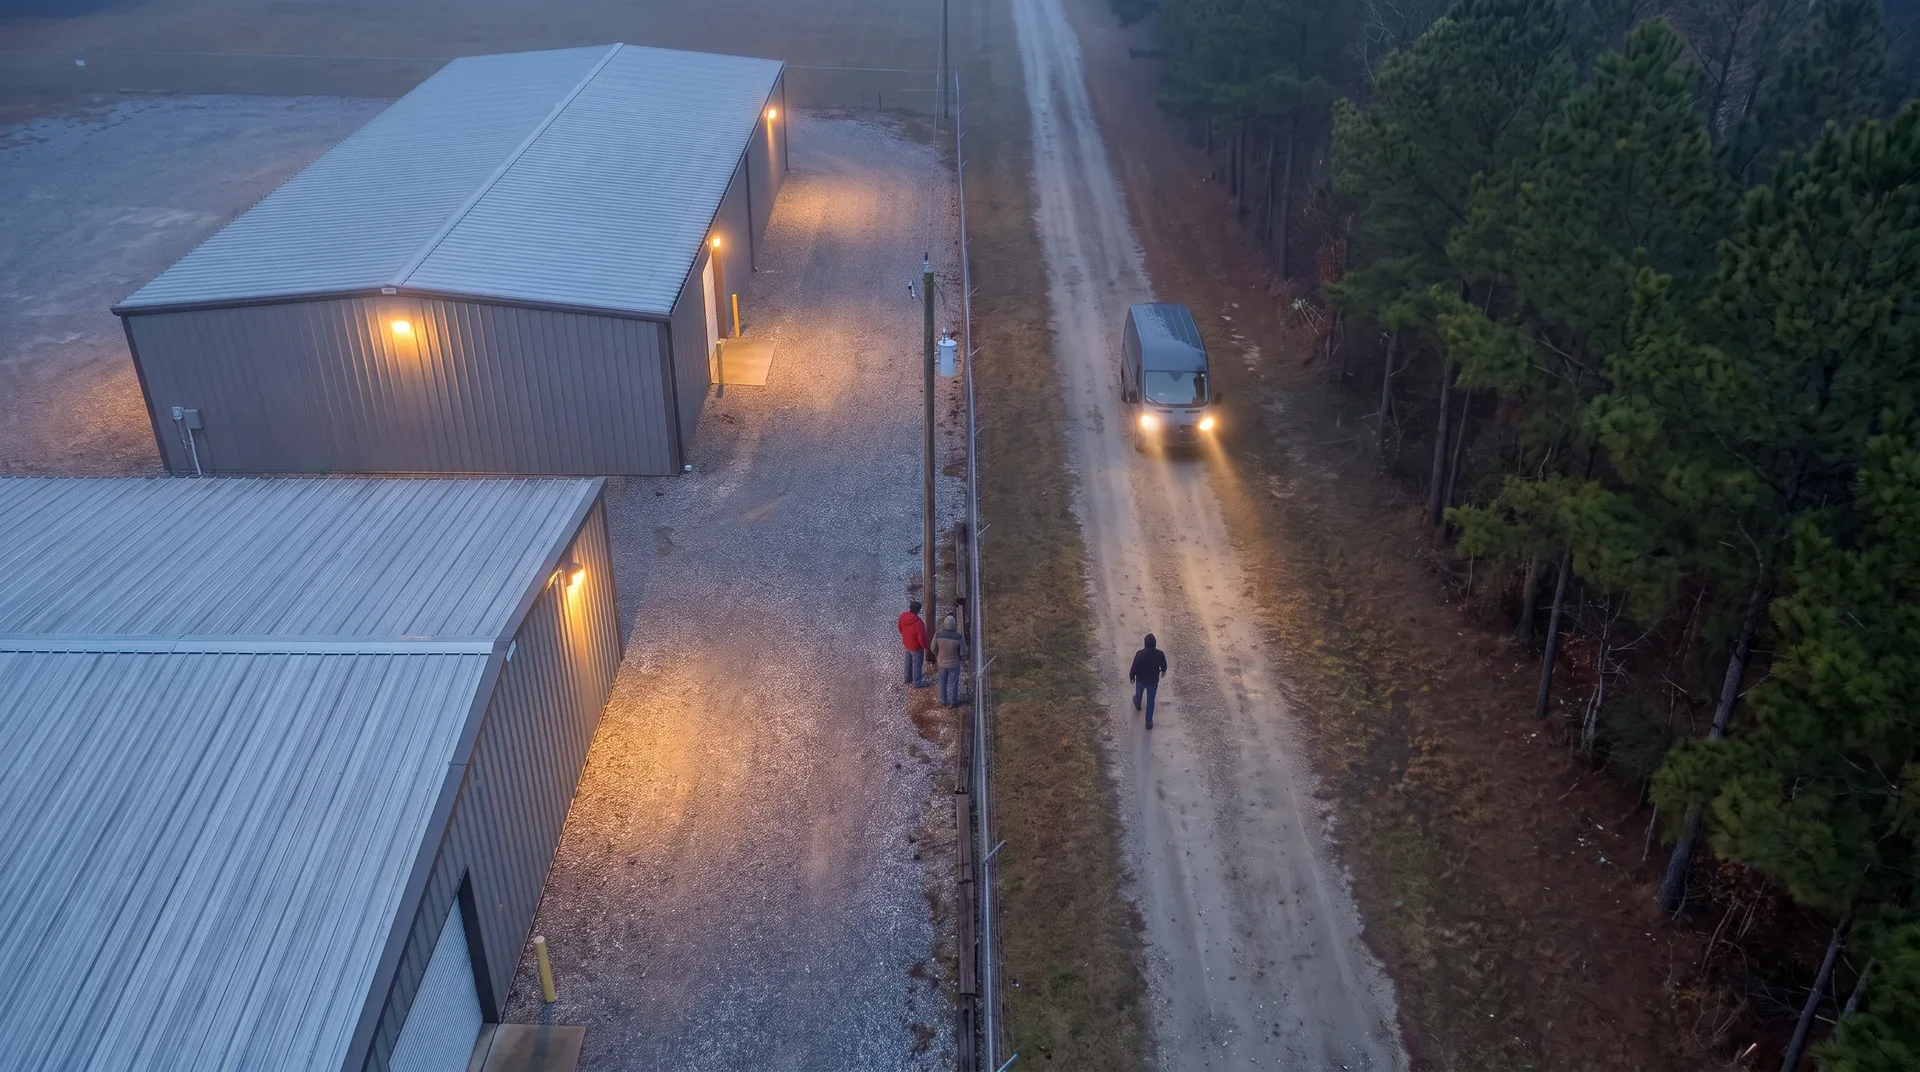
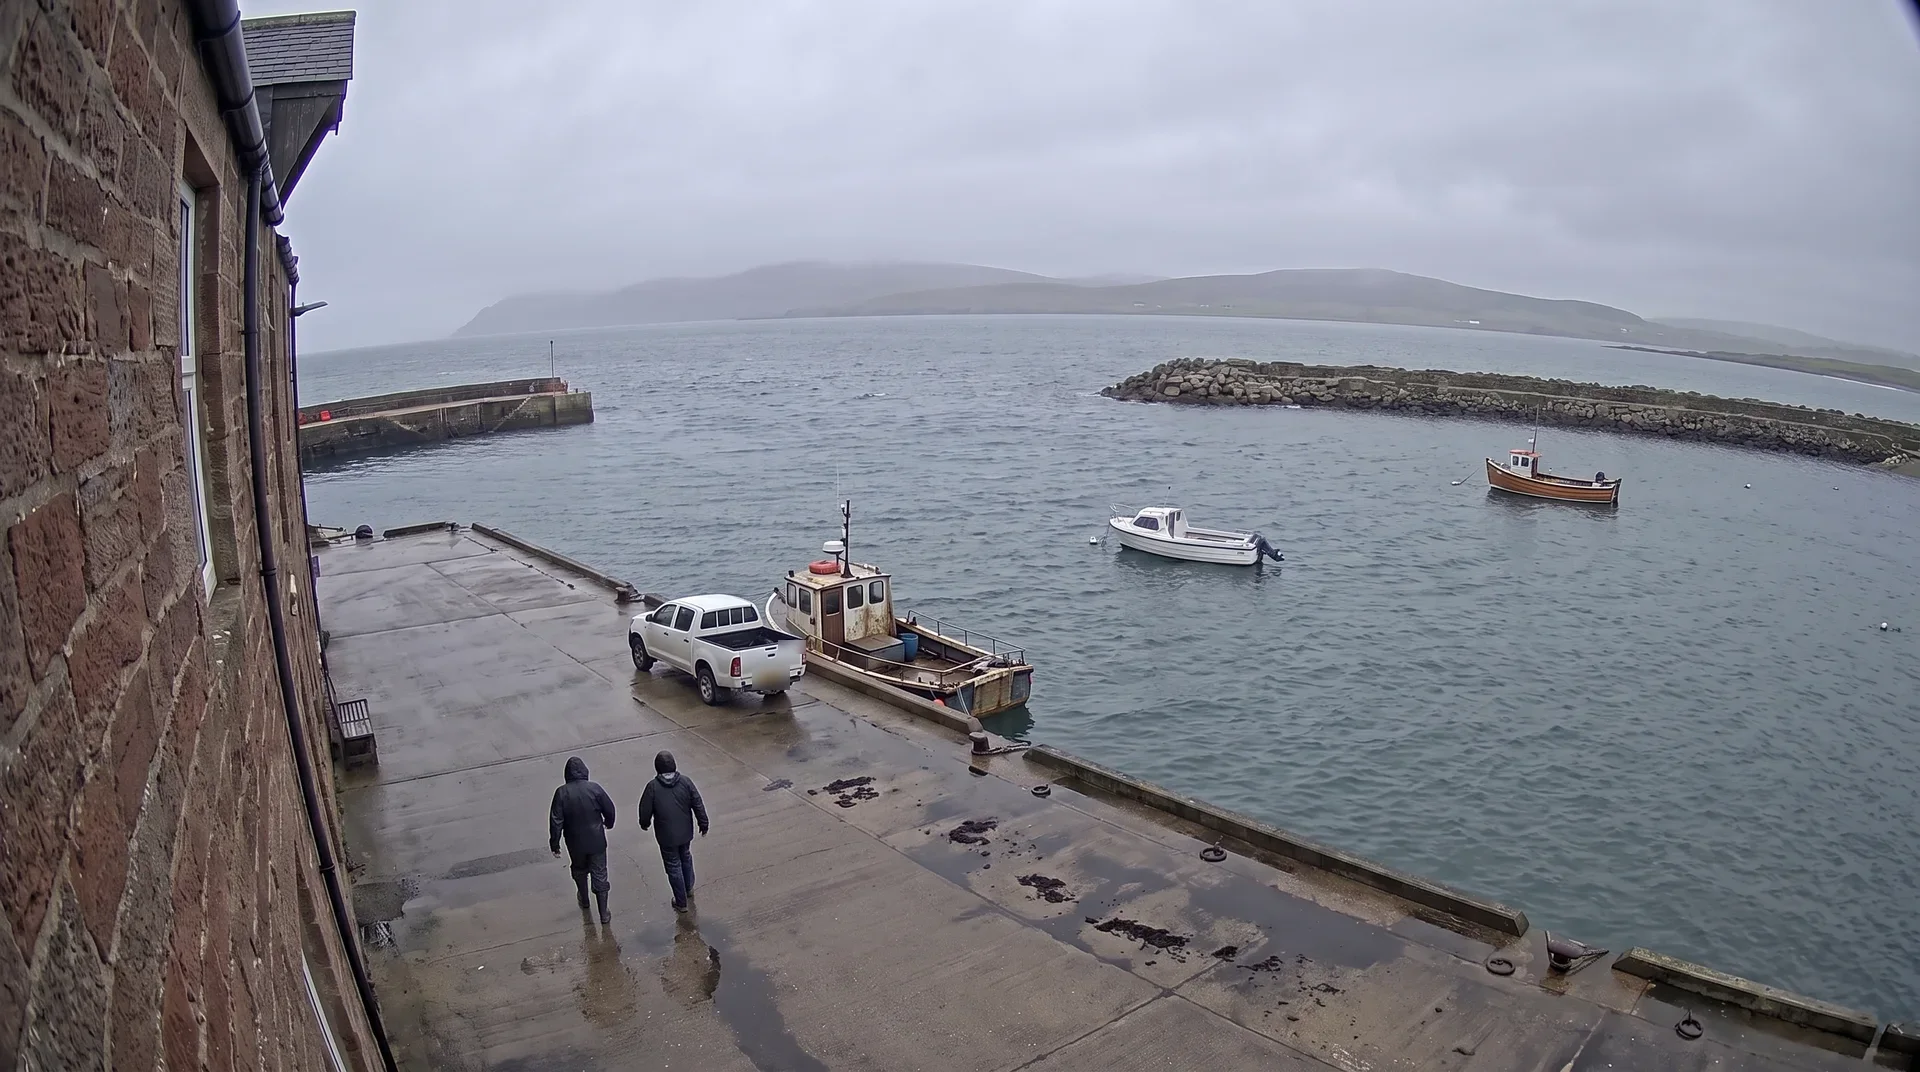
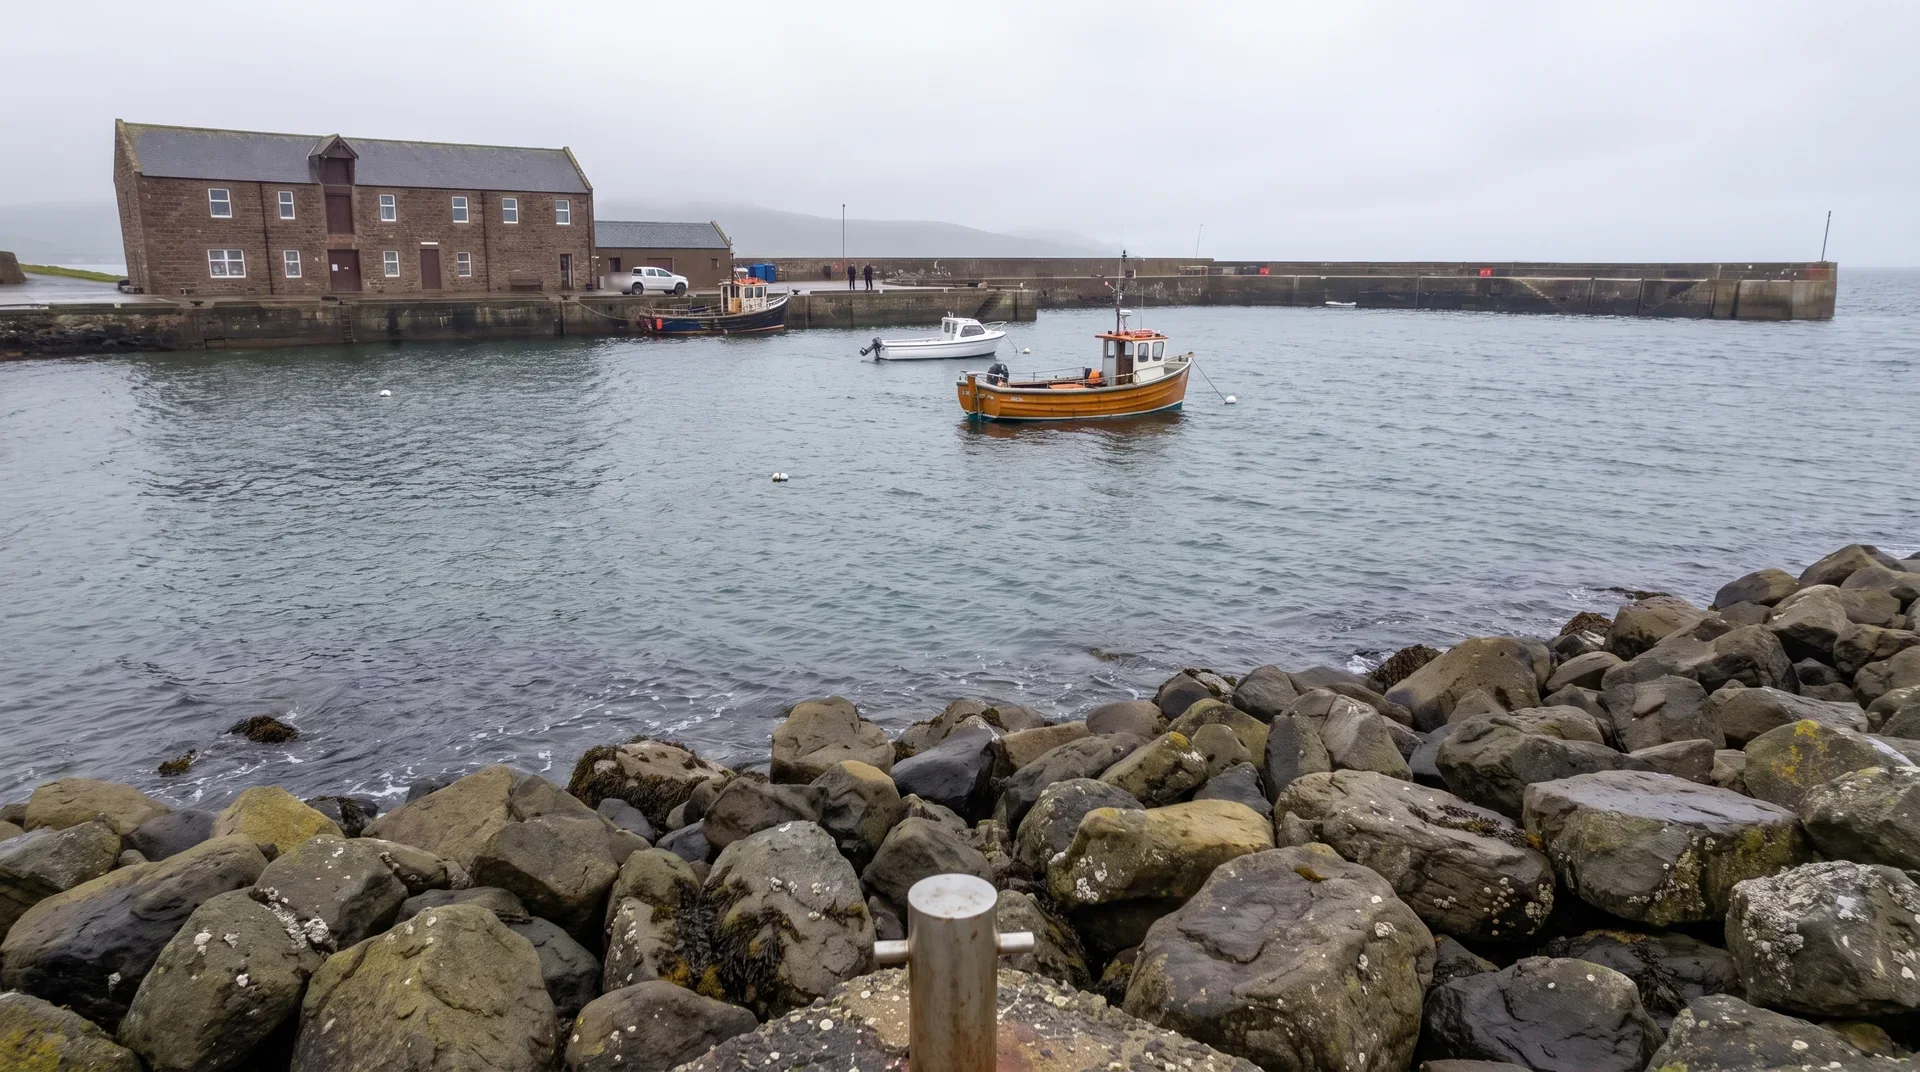
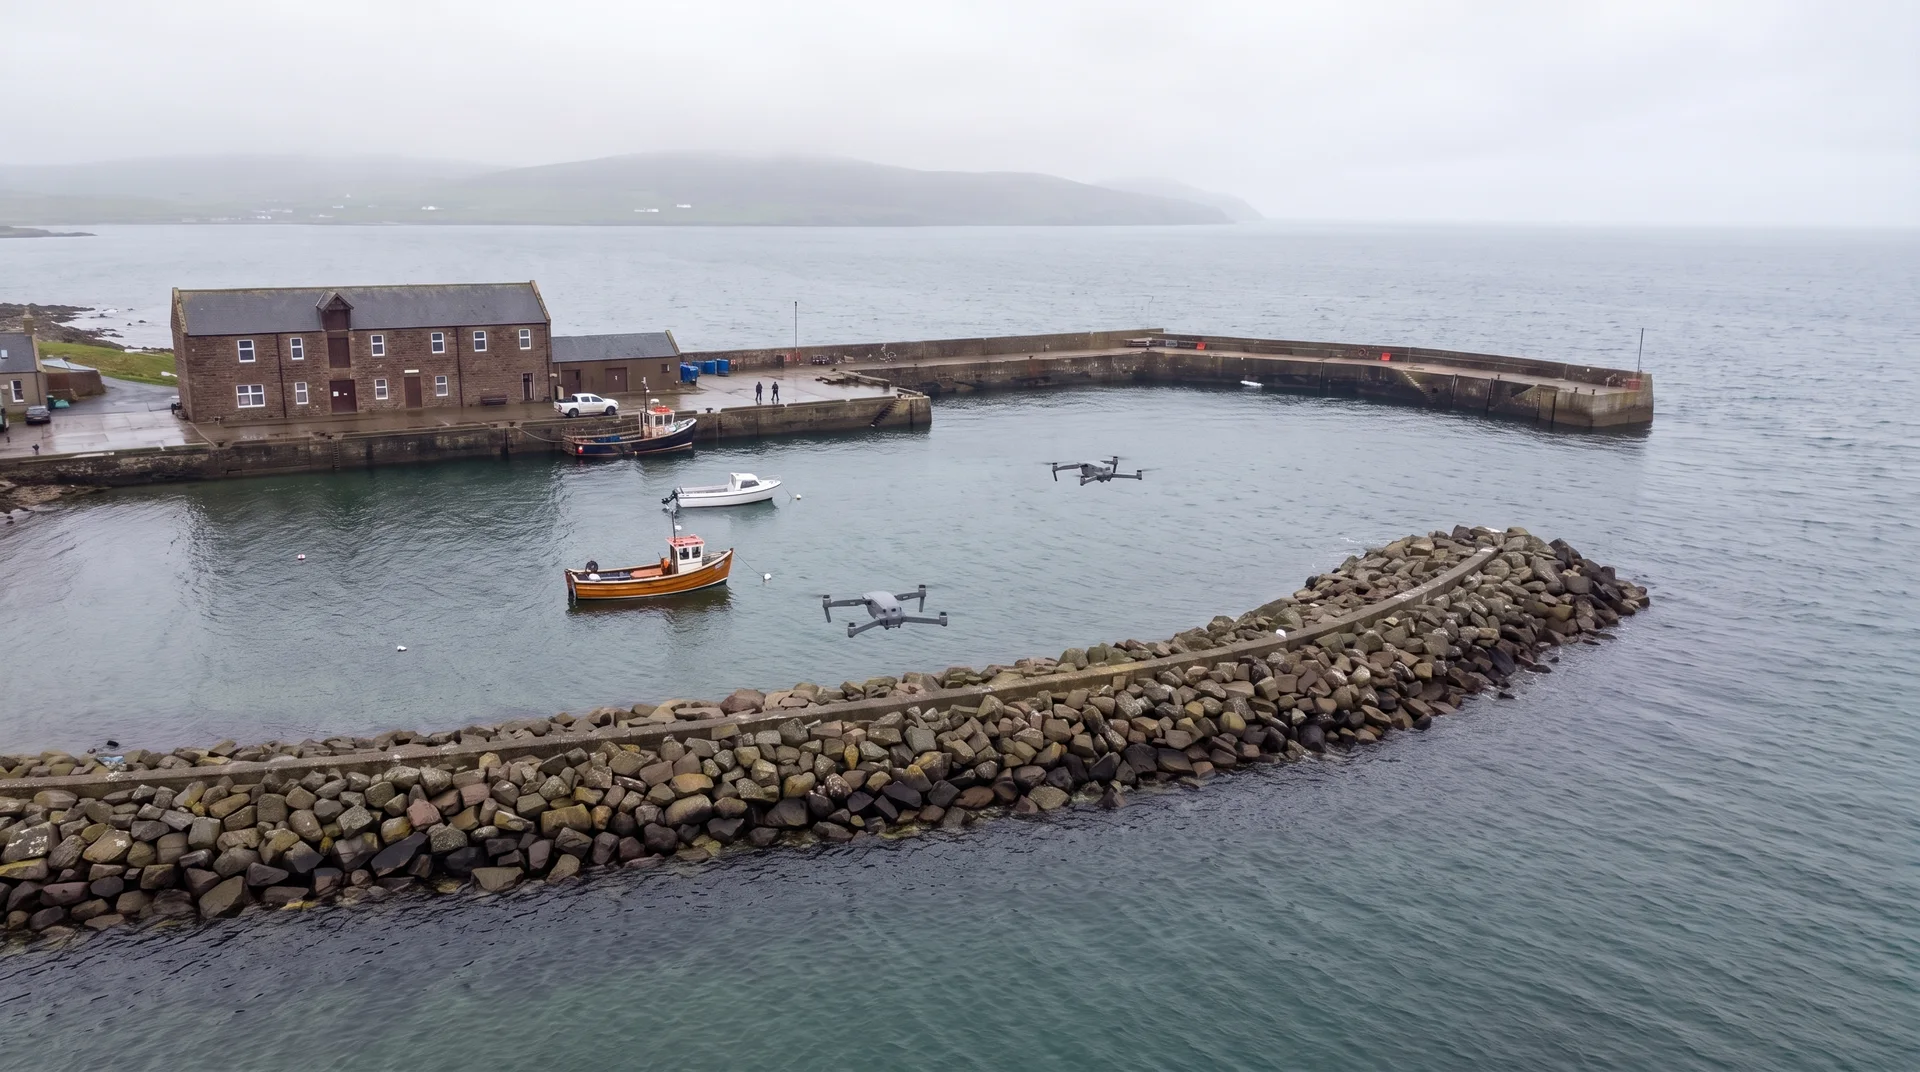
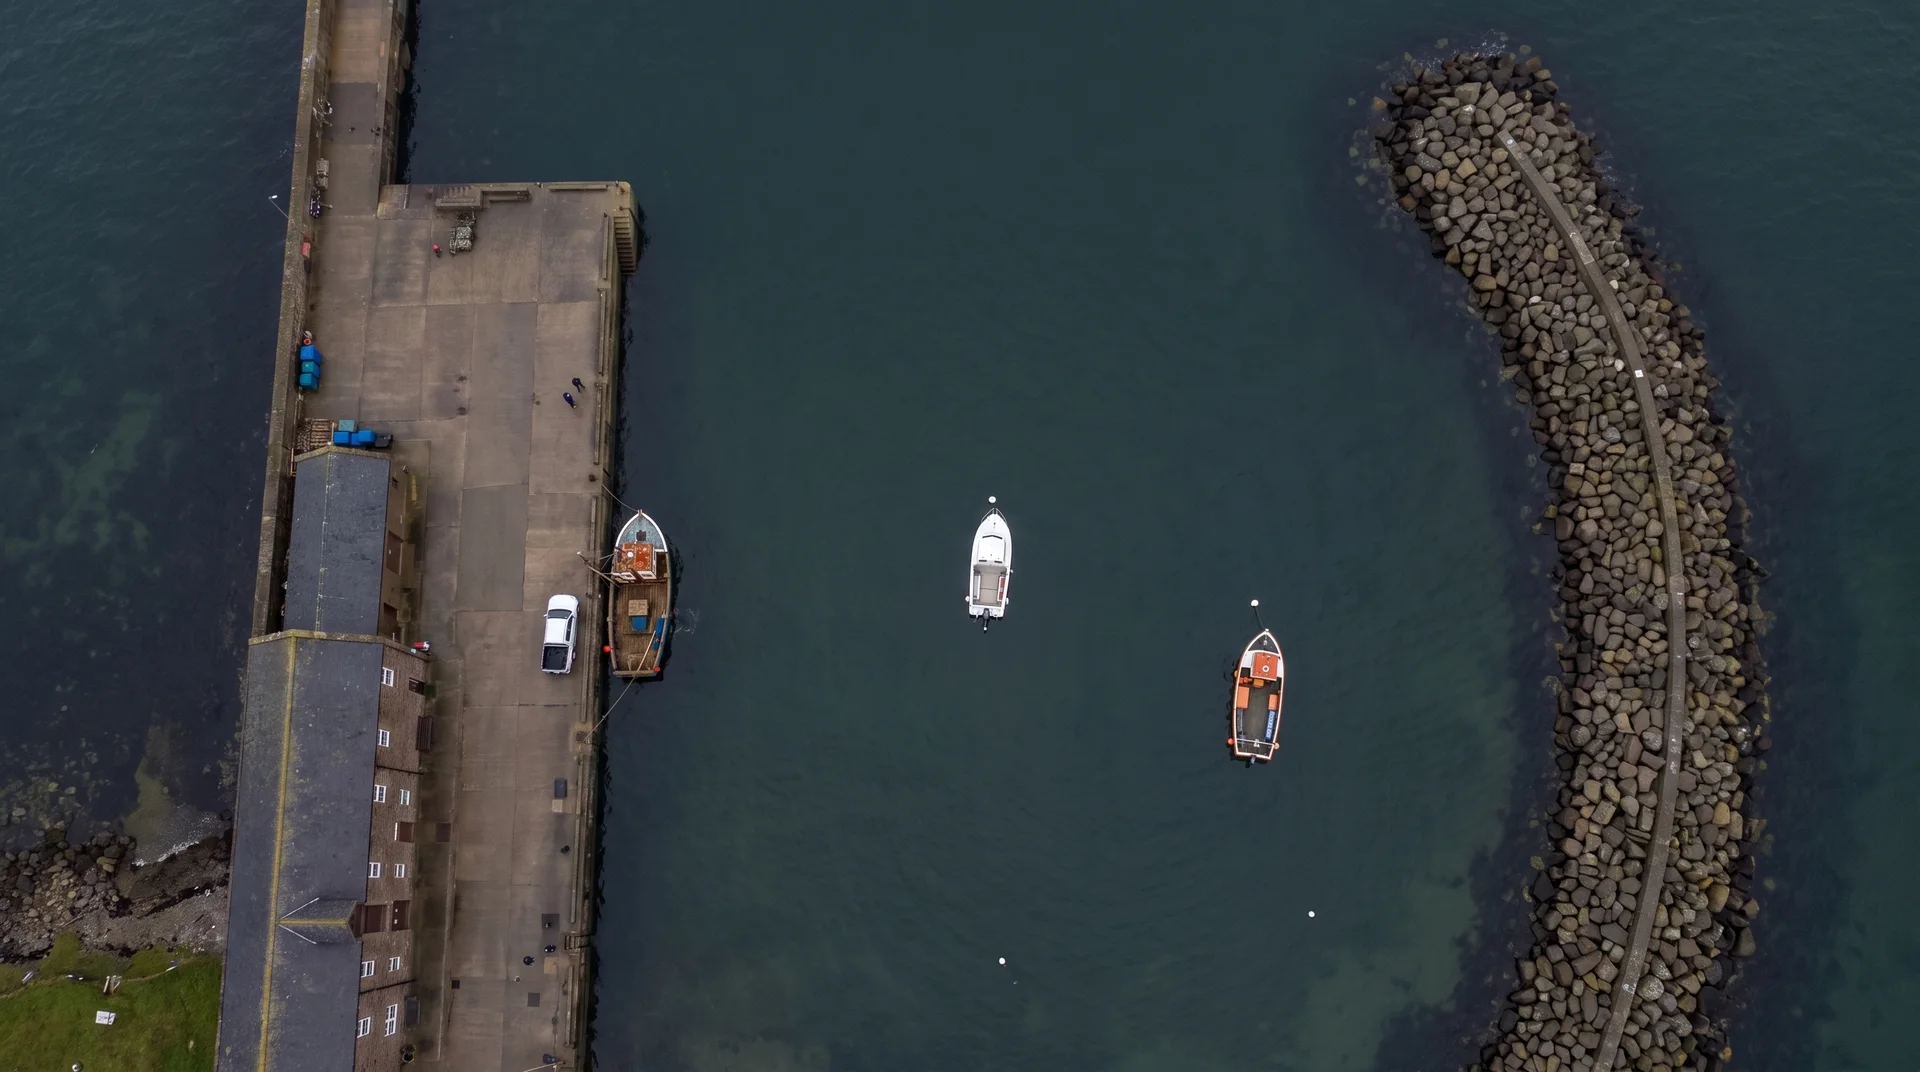
Four angles on one place: fixed cameras and the site's own drones. EdgeOS is built to know it is the same person in every view, keep following them, and tell the people on site.
 P2P3P1VH1
 P2P3P1VH1
 P2P3P1VH1D1 Own droneD2 Own drone
 P2P3P1VH1
 P4P5VH2VS1VS2VS3
 P4P5VH2VS1VS2VS3
 P4P5VH2VS1VS2VS3D3 Own droneD4 Own drone
 P4P5VH2VS1VS2VS3
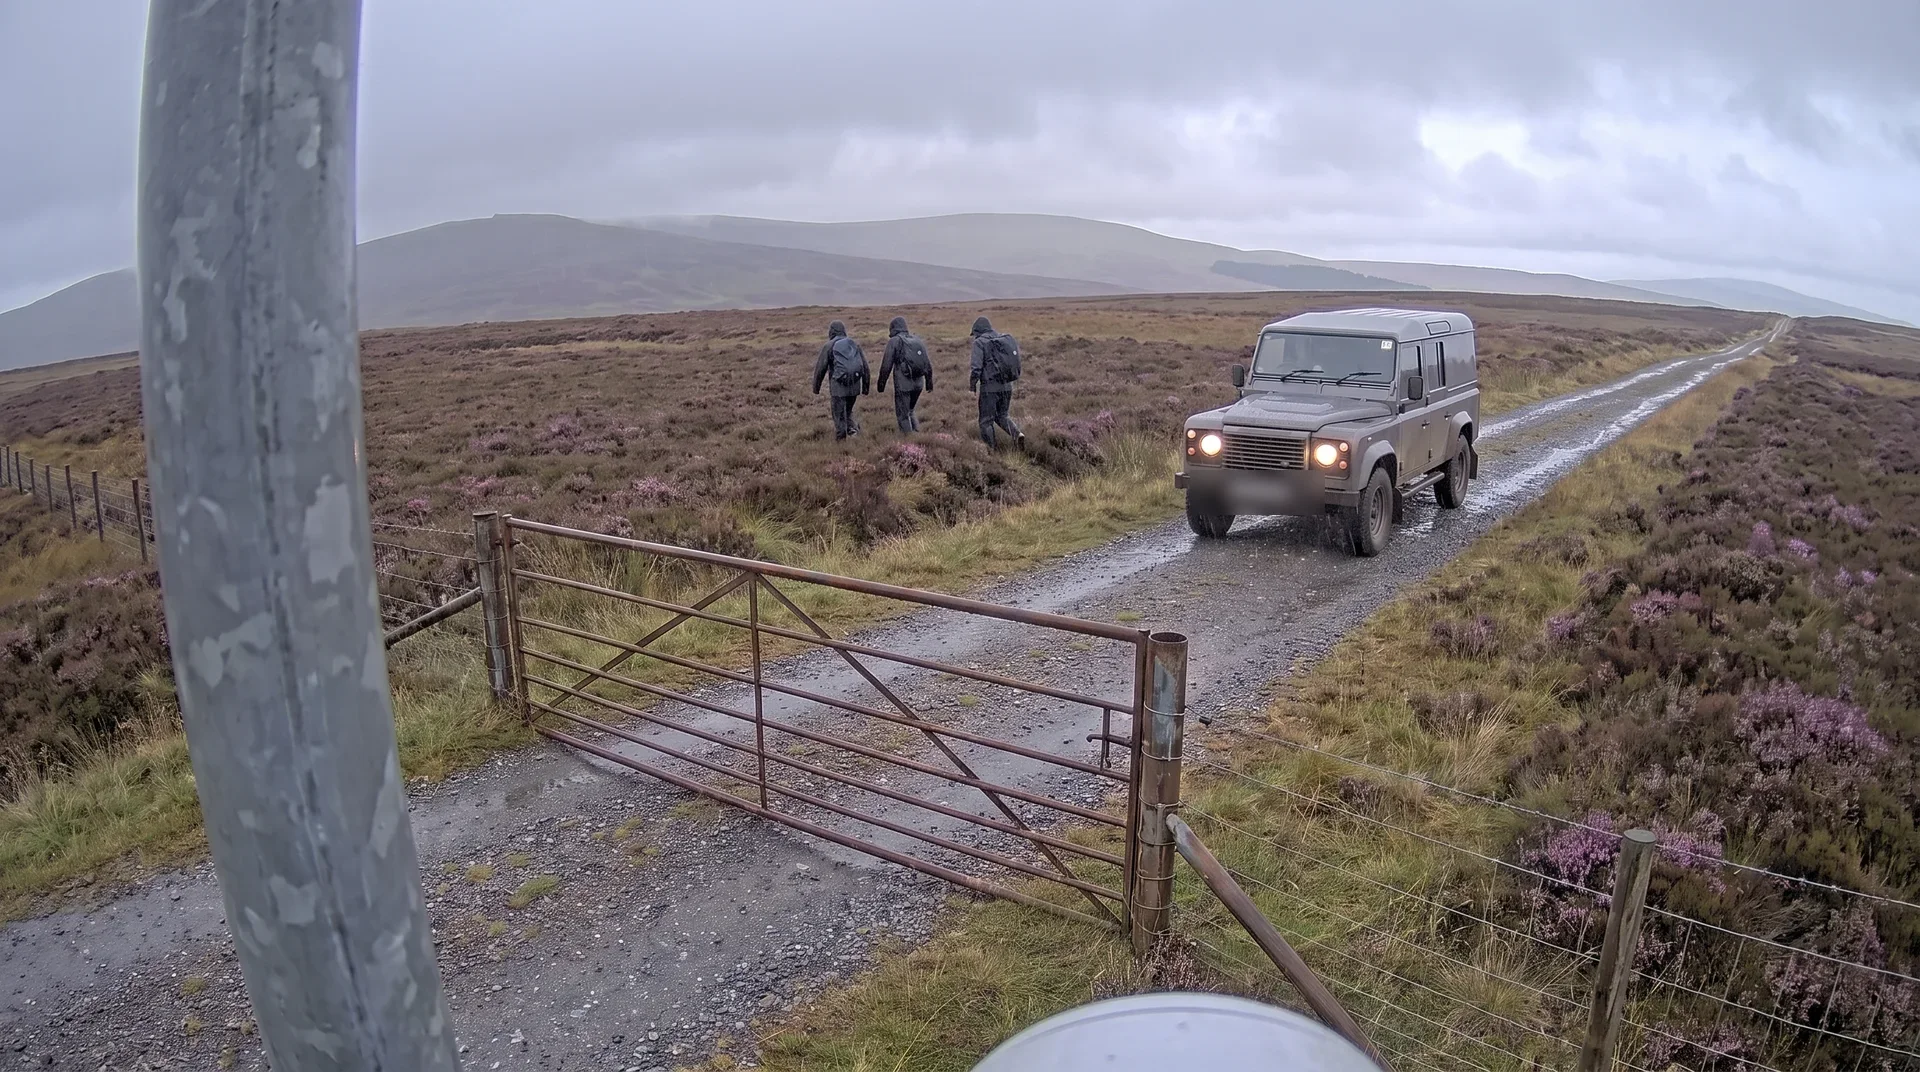 P6P7P8VH3
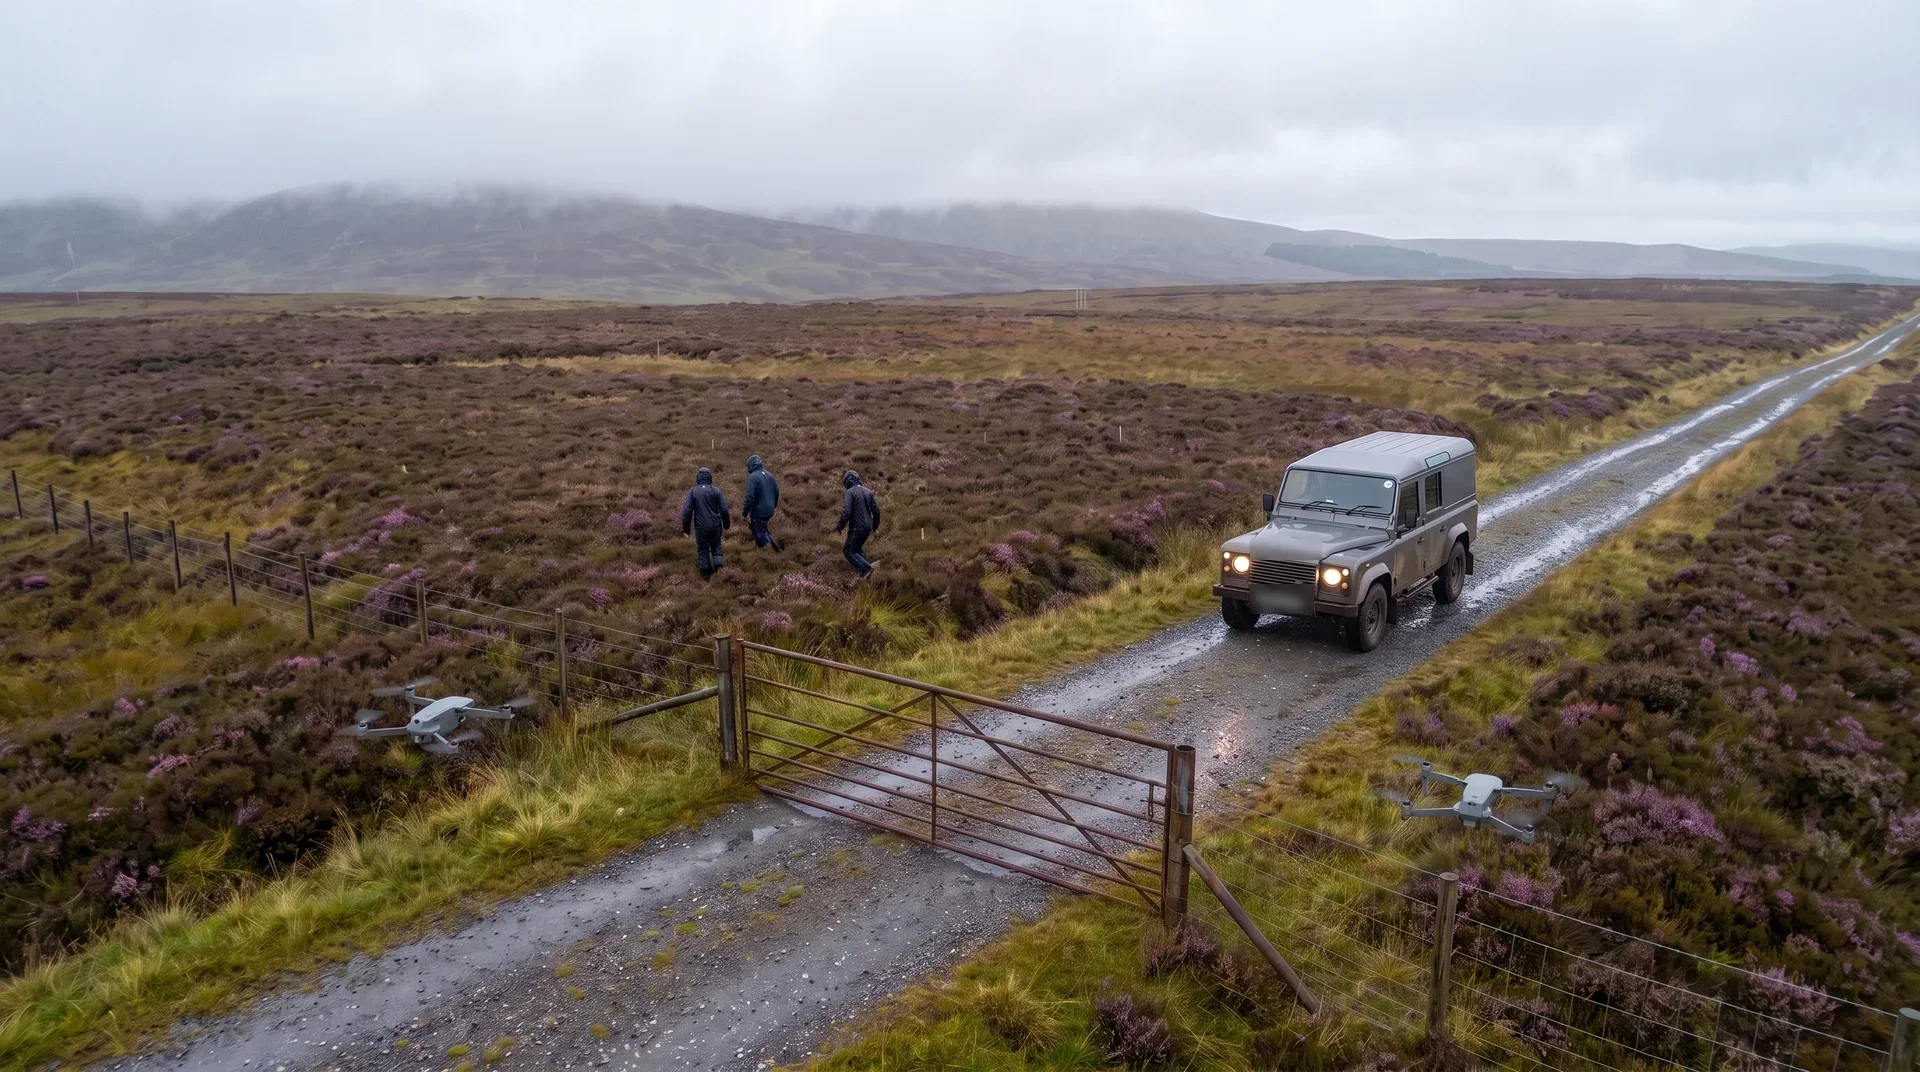 P6P7P8VH3D5 Own droneD6 Own drone
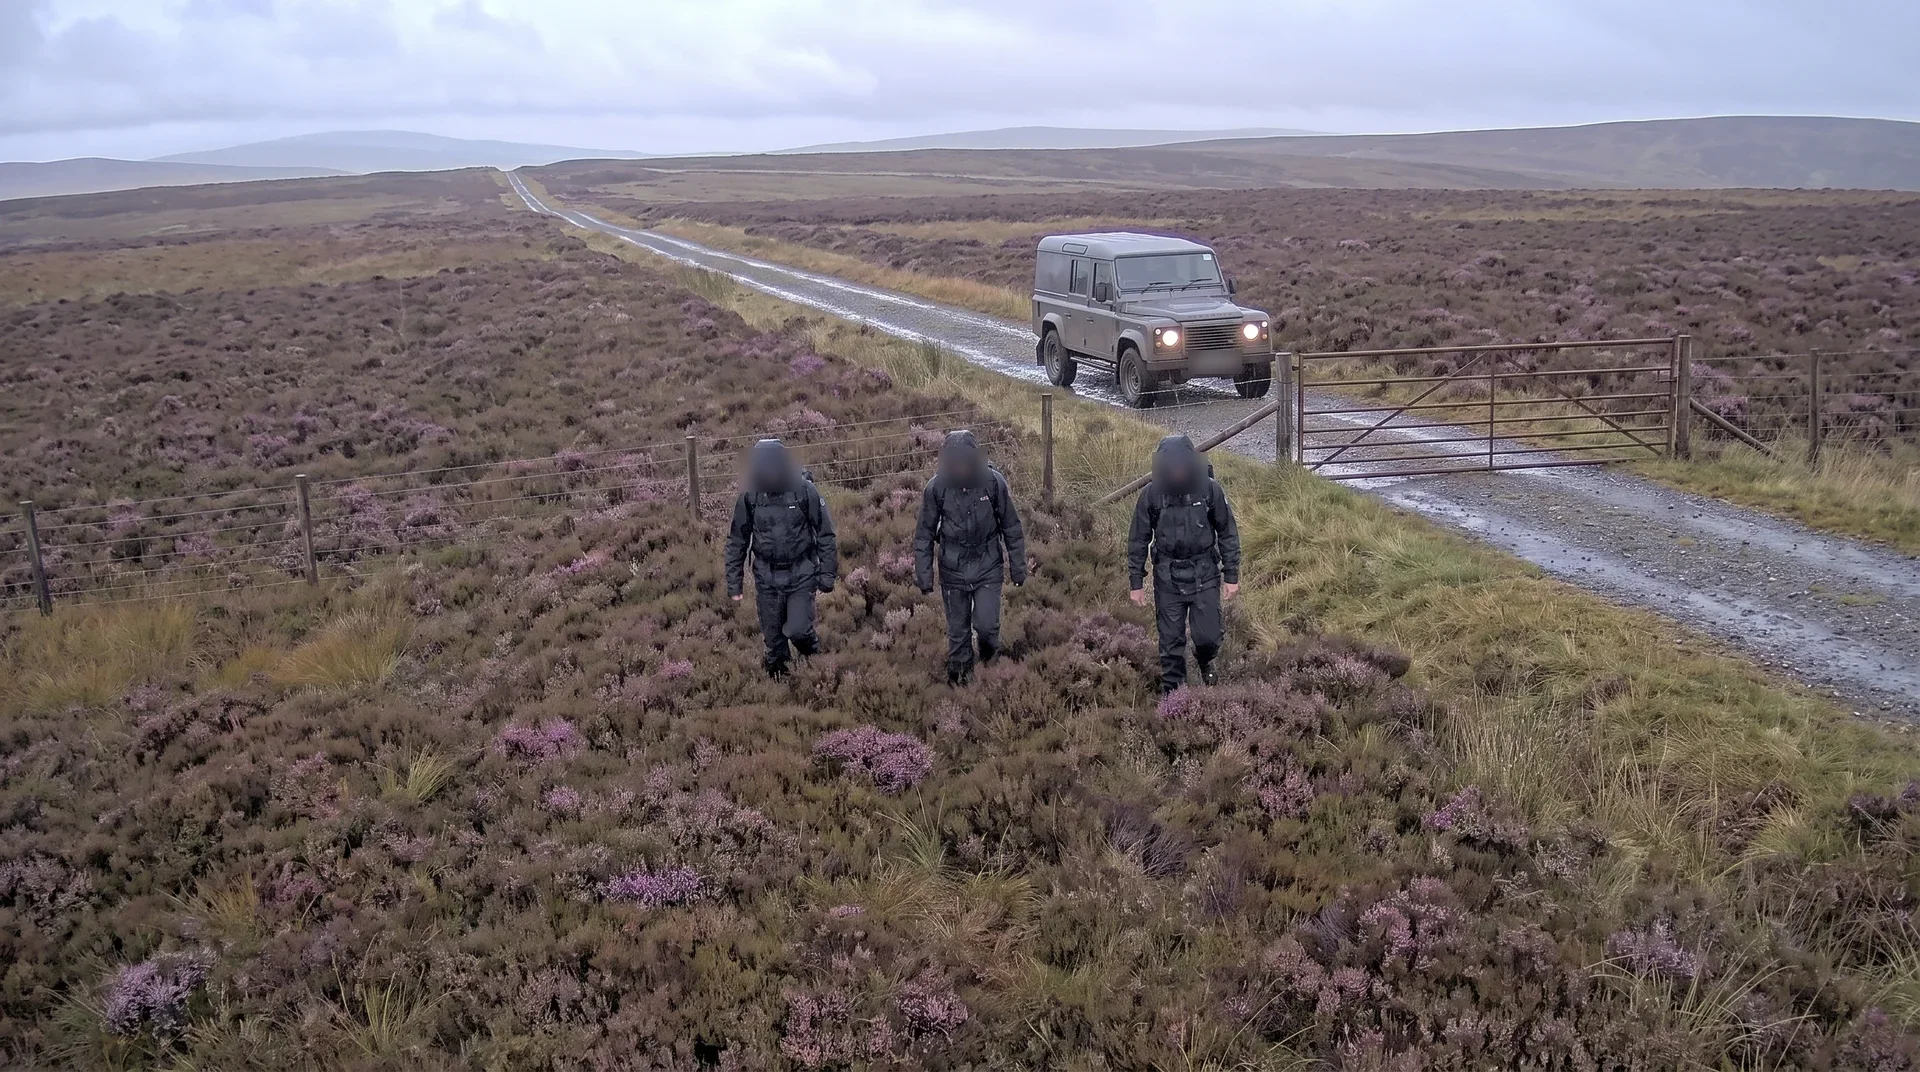 P8P7P6VH3
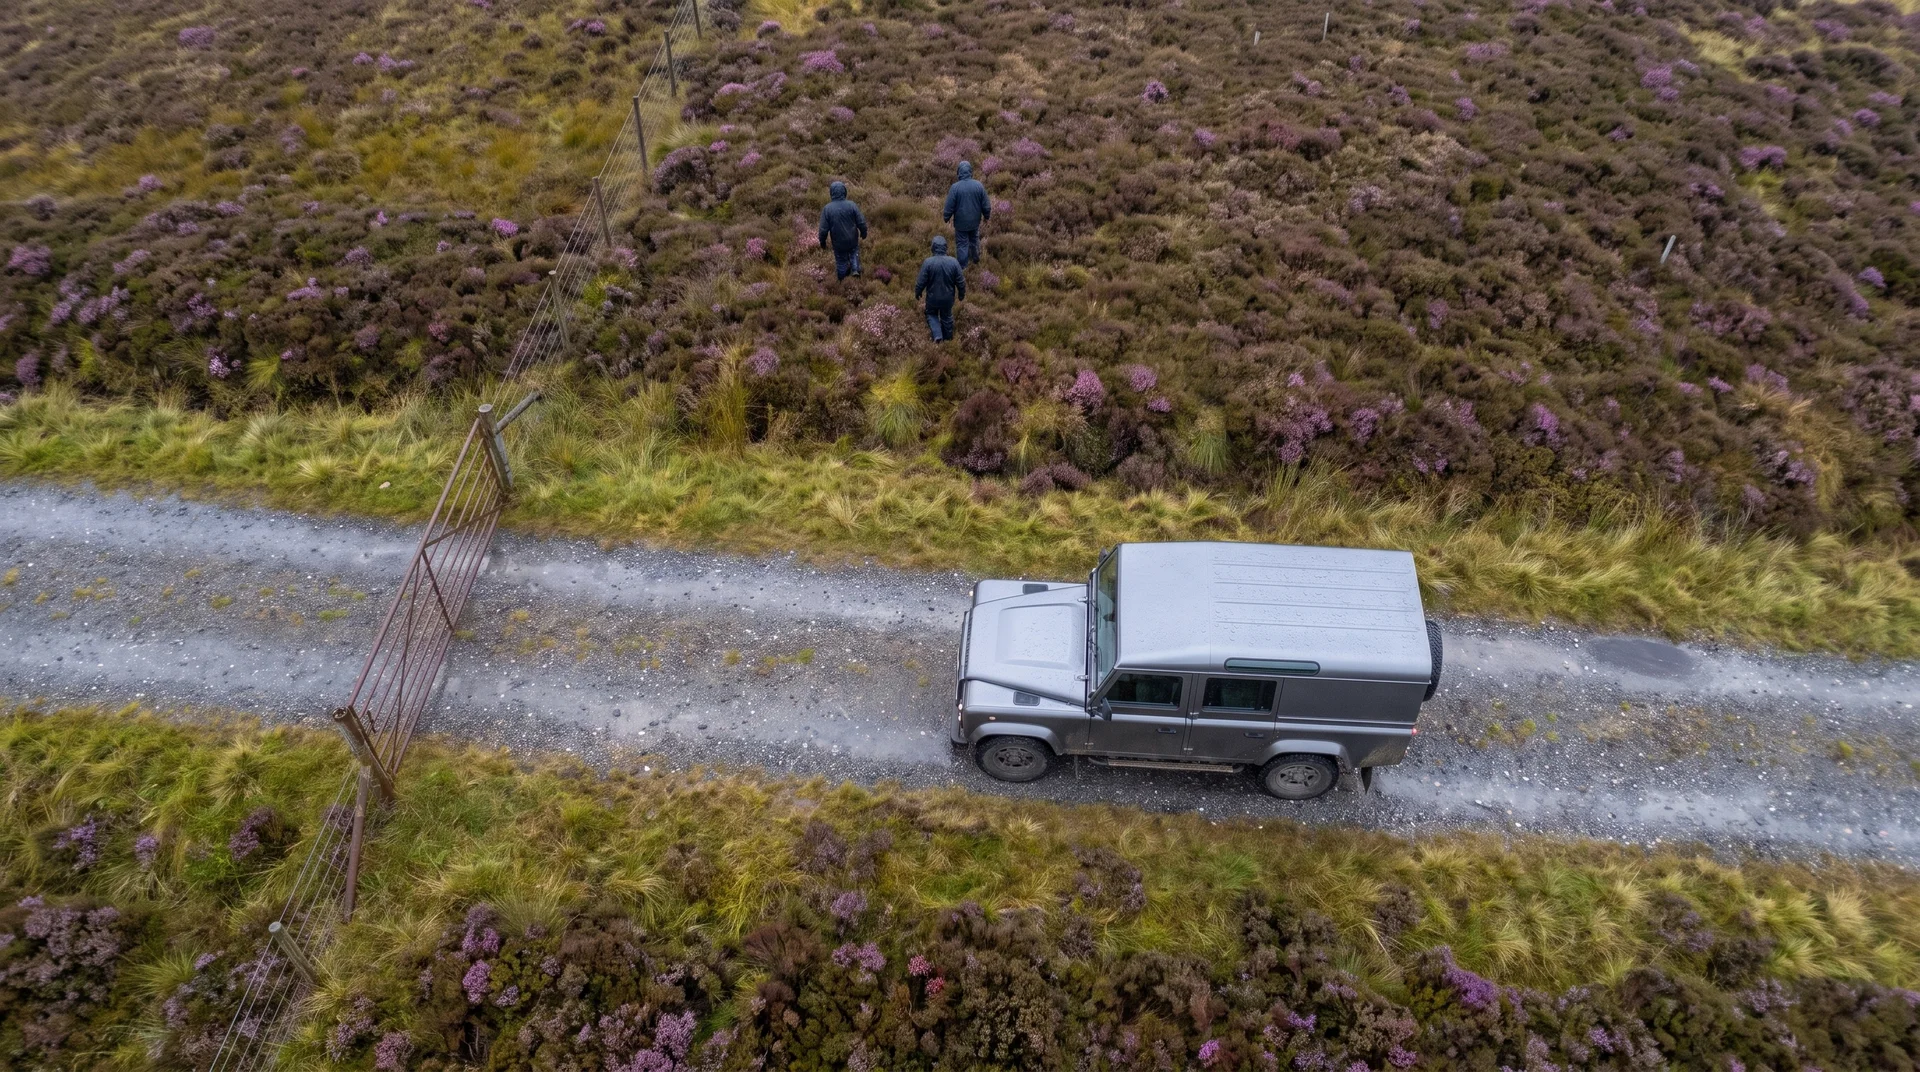 P6P7P8VH3
Illustration only, not the EdgeOS interface. Generated images: no real sites, people or decisions. Matching one object across sensors and flagging it are what EdgeOS is built to do.
Capabilities
Detection, tracking and fusion run on the node. No data centre, no cloud, no link required.
Anything that reports a measurement can be fused, one adapter per sensor type. Cameras of every kind, drone video, radar and lidar today.
EdgeOS sends tracks and events, not streams: more than 99.9% less radio traffic than four HD camera feeds (modelled).
If the link drops, results wait on the node and go when it returns. Zero events lost across 77 days of field data.
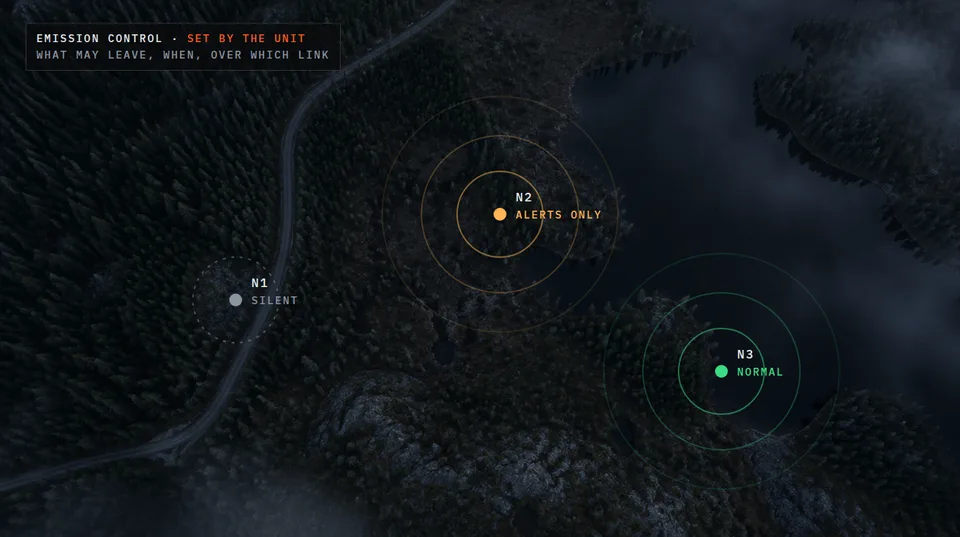
Emission control in the software: the unit decides what may leave the node, when, and over which link.
Tracks and events go into Palantir Foundry today. Built to feed other C2 and mission systems through adapters.
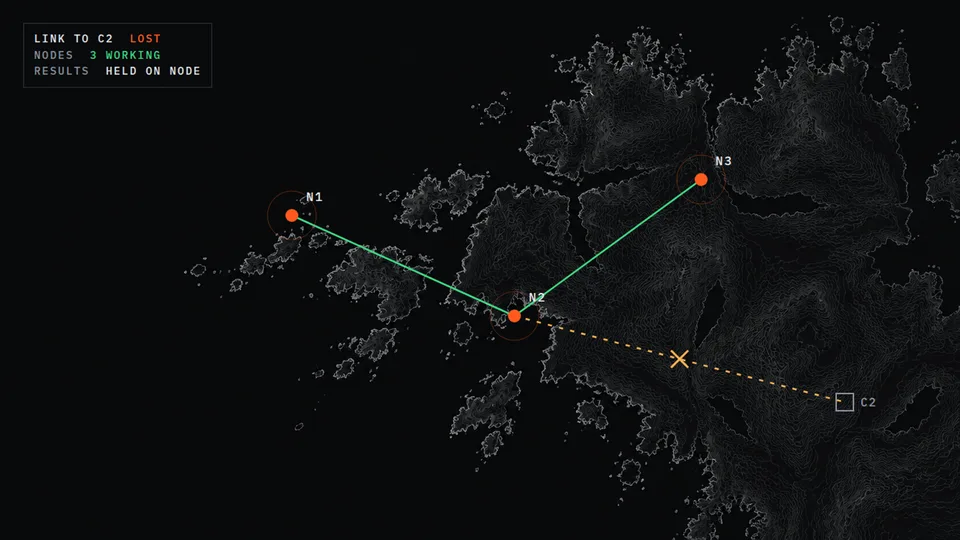
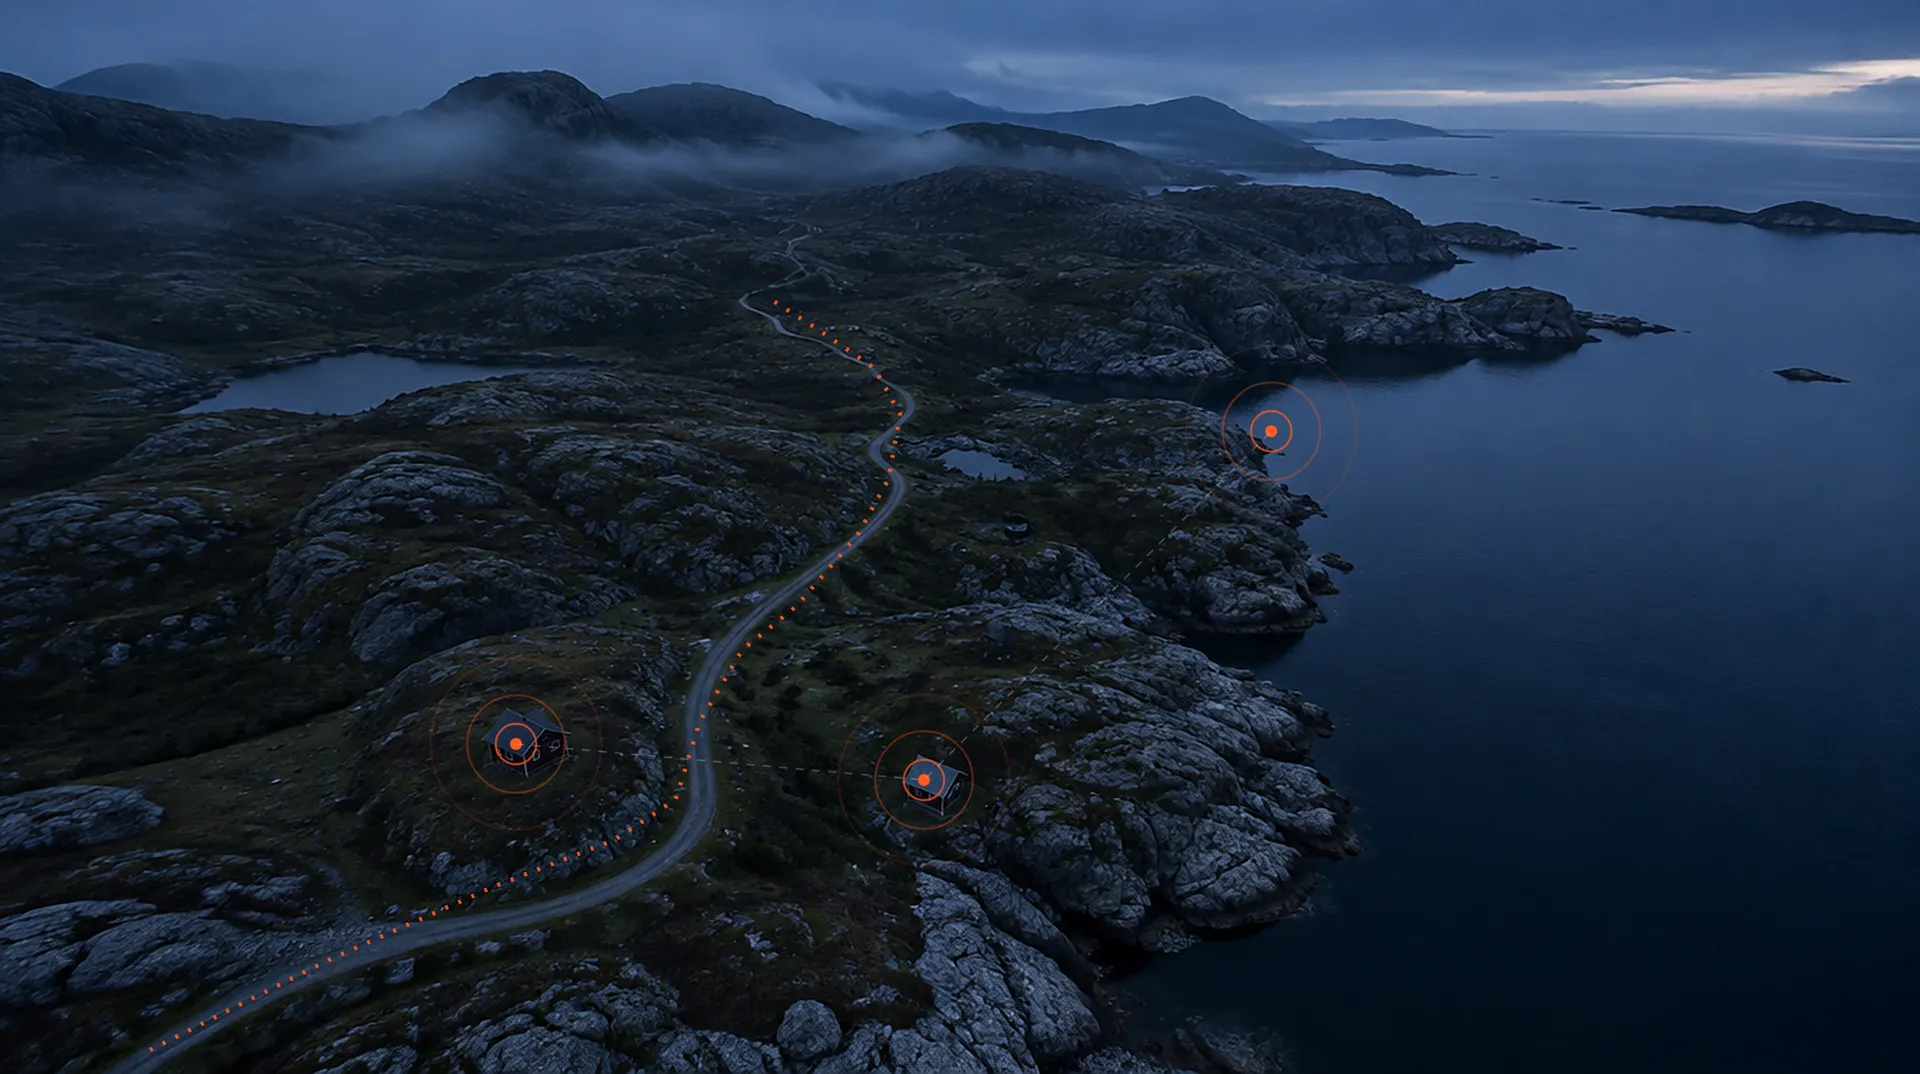
Where EdgeOS goes
In numbers
79ms
Detection on the node to Palantir Foundry
Measured232ms
Camera glass to the operator's screen
Measured0
Events lost across 77 days of field data
Verified> 99.9%
Less radio traffic than four HD camera streams
Modelled01 / 05
Runs on
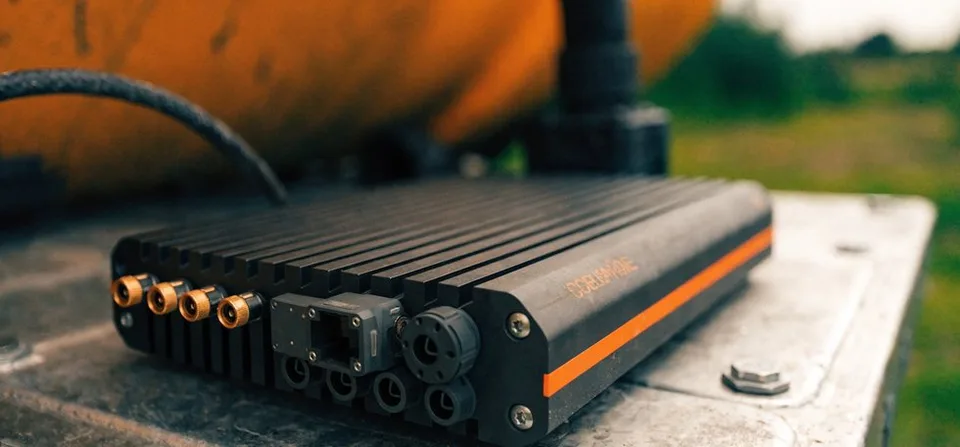
EdgeOS is hardware-agnostic: it runs on our own nodes, HP-FN1 and HP-FN1 Micro, or on the edge compute a platform already carries.
02 / 05
Inputs
Links to the sensors already in place.
03 / 05
On the node
AI models run on the node itself, on every connected feed.
04 / 05
The picture
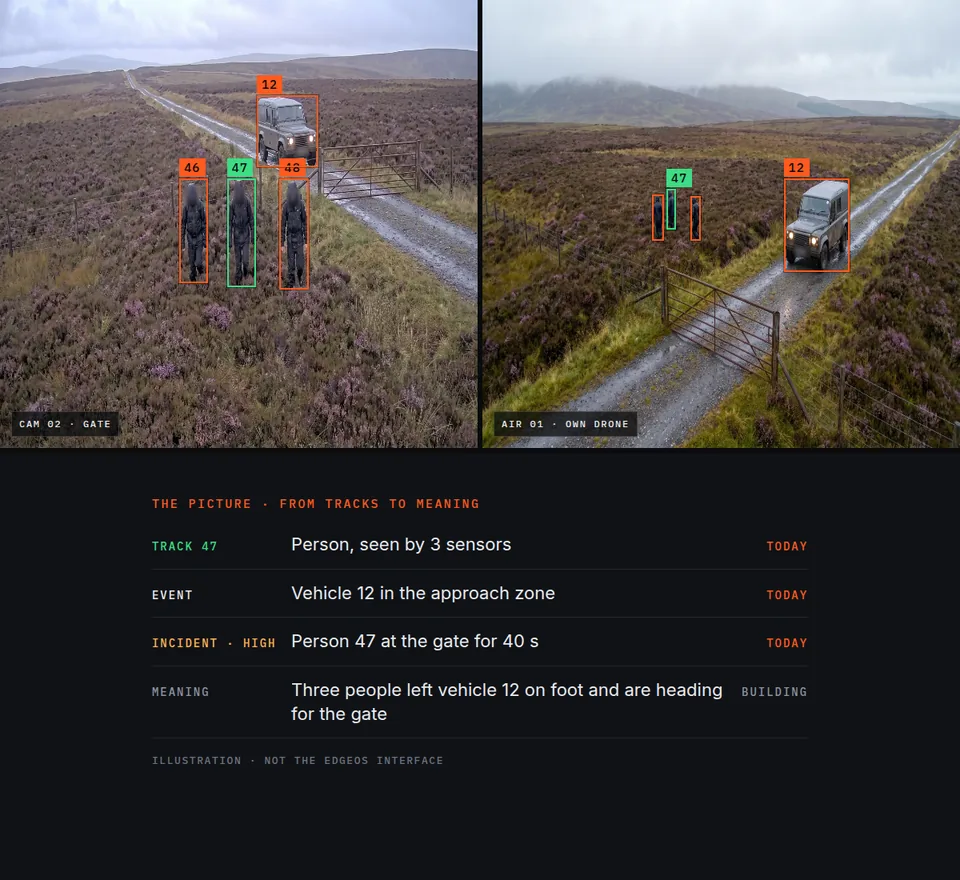
One picture from every sensor, and what is happening in it.
05 / 05
On site
Keeps running with no outside link, and decides what leaves the node.
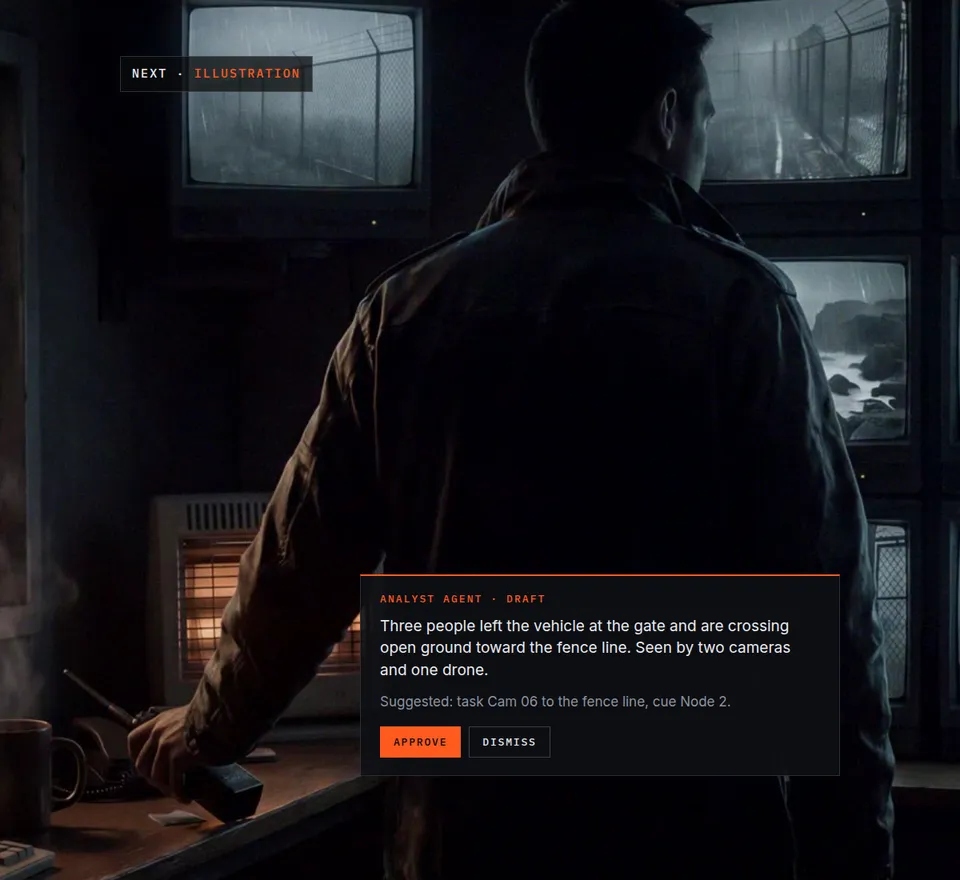
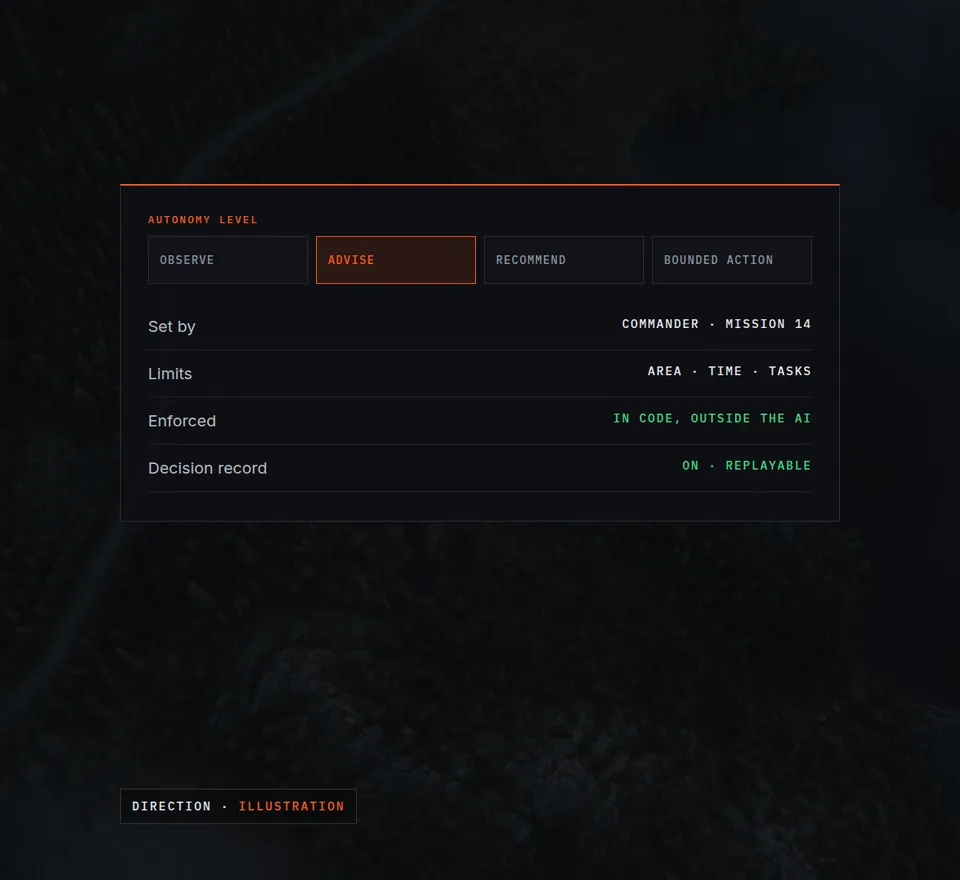
Not today. EdgeOS shows people what it finds, and people decide what happens next. Where autonomy goes further, the commander sets its limits, mission by mission.
No. It connects to the cameras and sensors already in place.
No. Everything runs on the node. When there is a link, EdgeOS uses it within the limits the unit sets. When the link drops, results wait on the node and go when it returns.
Only where the unit allows. The unit sets what may leave the node, when and over which link. Tracks and events are what travel.
Cameras of every kind: IP, GMSL, infrared and thermal. Drone video with KLV, radar and lidar, with GNSS and IMU for position. Ask us about yours.
Yes. Every node publishes into the same picture in Palantir Foundry today. Nodes sharing one picture directly, with no central system, is what we are building now.